Task-Agnostic Control and Customization
Development of task-agnostic control paradigms and human-in-the-loop customization frameworks for robotic assistance across users and daily activities.
Explore control and customization →Clemson University · Assistive Robotics Laboratory
We investigate control, customization, design, and evaluation methodologies for robotic systems that assist humans across daily activities.
ARL · Research mission
The mission of the Assistive Robotics Laboratory is to develop agile, versatile robotic systems to assist humans across daily activities.
Our research connects task-agnostic control and customization, wearable device prototyping, and biomechanics studies. We investigate these directions through mathematical analysis, simulation, hardware development, and experimental evaluation.
ARL research program →ARL research program
Development of task-agnostic control paradigms and human-in-the-loop customization frameworks for robotic assistance across users and daily activities.
Explore control and customization →Design, development, and prototyping of user-friendly wearable robotic devices for assistance of human motion.
Explore device development →Experimental validation and biomechanical studies to characterize human movement, physical human–robot interaction, and the effects of robotic assistance.
Explore biomechanical evaluation →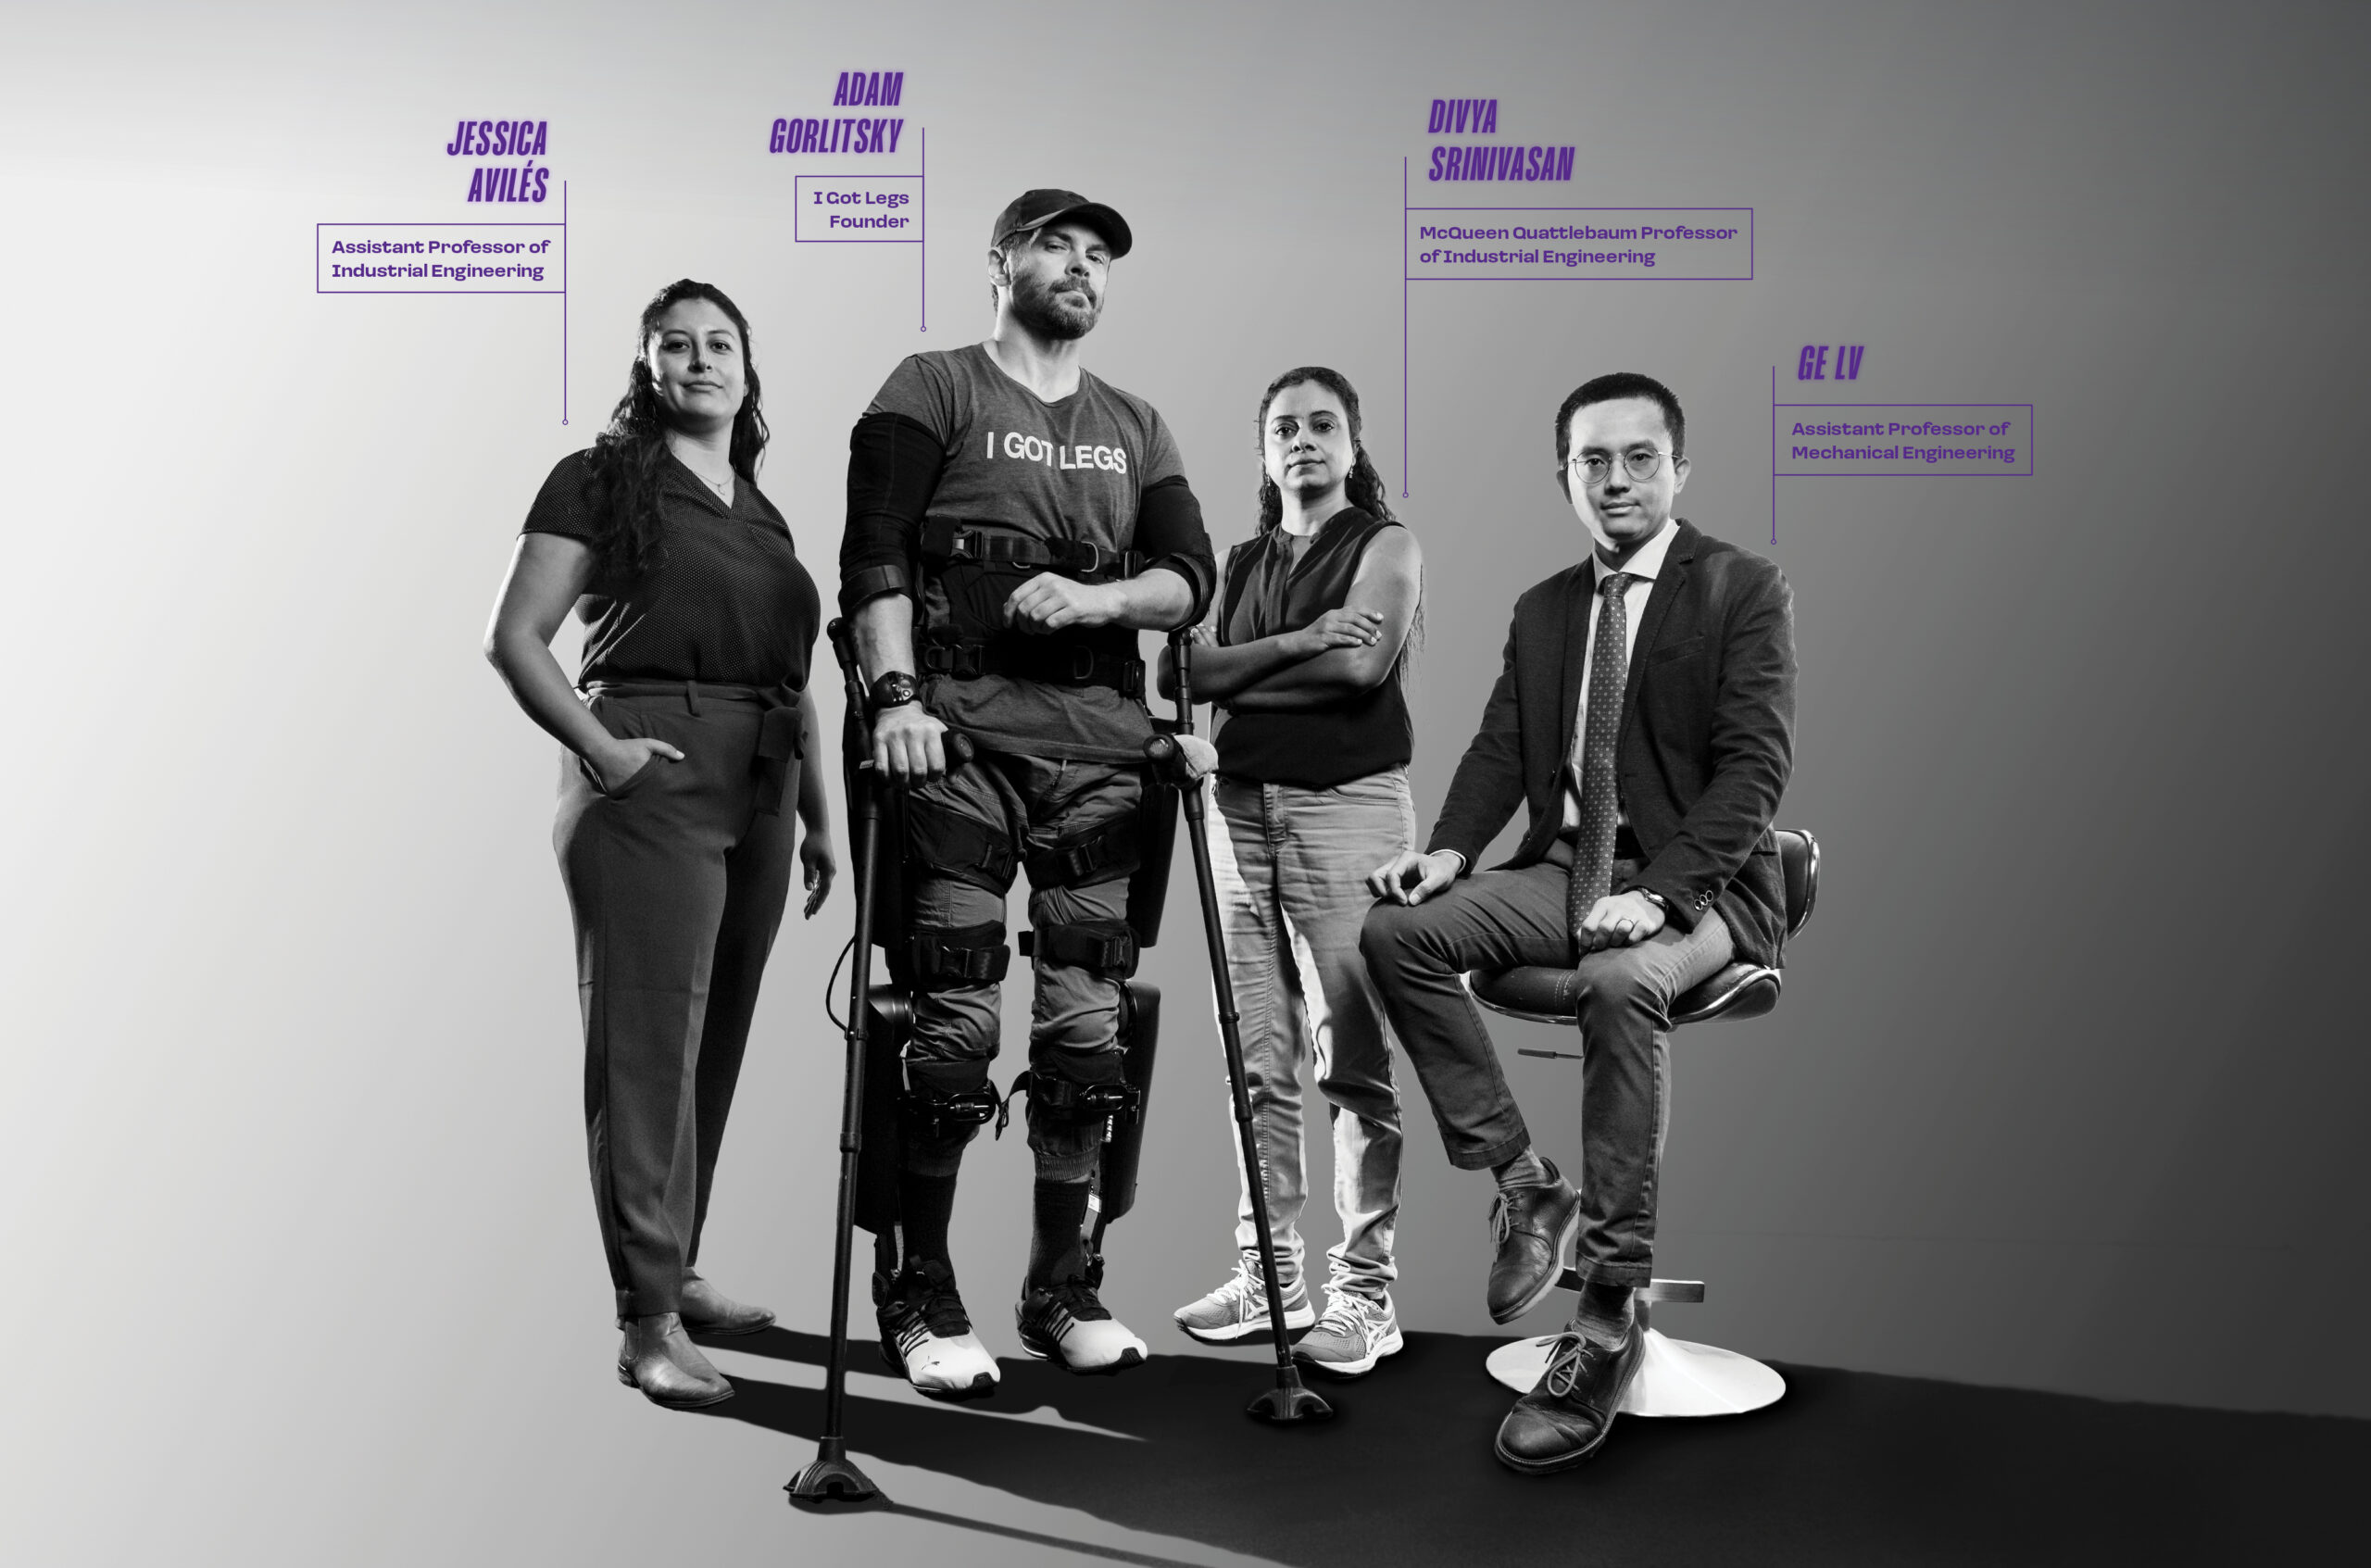
ARL in Clemson World
Clemson World features our research on wearable robotic systems for assistance of human locomotion.
Read the story →From the laboratory
Congratulations to Dr. Miao Yu on successfully defending his dissertation.
Dr. Lv received the ASME Rising Stars of Mechanical Engineering Award at IMECE 2025.
Dr. Lv delivered a talk at the ICRA 2025 lower-limb exoskeleton workshop.
Our research was featured in Clemson World.
Our exoskeleton research was featured by the College of Engineering, Computing and Applied Sciences and Clemson News. Watch the interview.
Dr. Lv was awarded the Dean’s Professorship in the College of Engineering, Computing and Applied Sciences.
Our paper, “Safety Augmentation for Volitional Human Locomotion via Lower-Limb Exoskeletons: A Case Study,” was accepted to IEEE Control Systems Letters.
Dr. Lv received the Mechanical Engineering Excellence Award (Junior Rank Faculty). Our Creative Inquiry team also presented at the 19th Annual Focus on Creative Inquiry Poster Forum.

Our lab received an NSF CAREER Award. “The Claw: An Avian-Inspired, Large Scale, Hybrid Rigid-Continuum Gripper,” a collaboration with Prof. Ian Walker, was also accepted as a cover article in the Robotics special issue “Intelligent Bionic Robots.”
Our paper, “A Two-Layer Human-in-the-Loop Optimization Framework for Customizing Lower-Limb Exoskeleton Assistance,” was published in the invited session “Recent Advancement of Human Autonomy Interaction & Integration” at the American Control Conference in San Diego.
Congratulations to Dr. Therese Parr on successfully defending her dissertation.
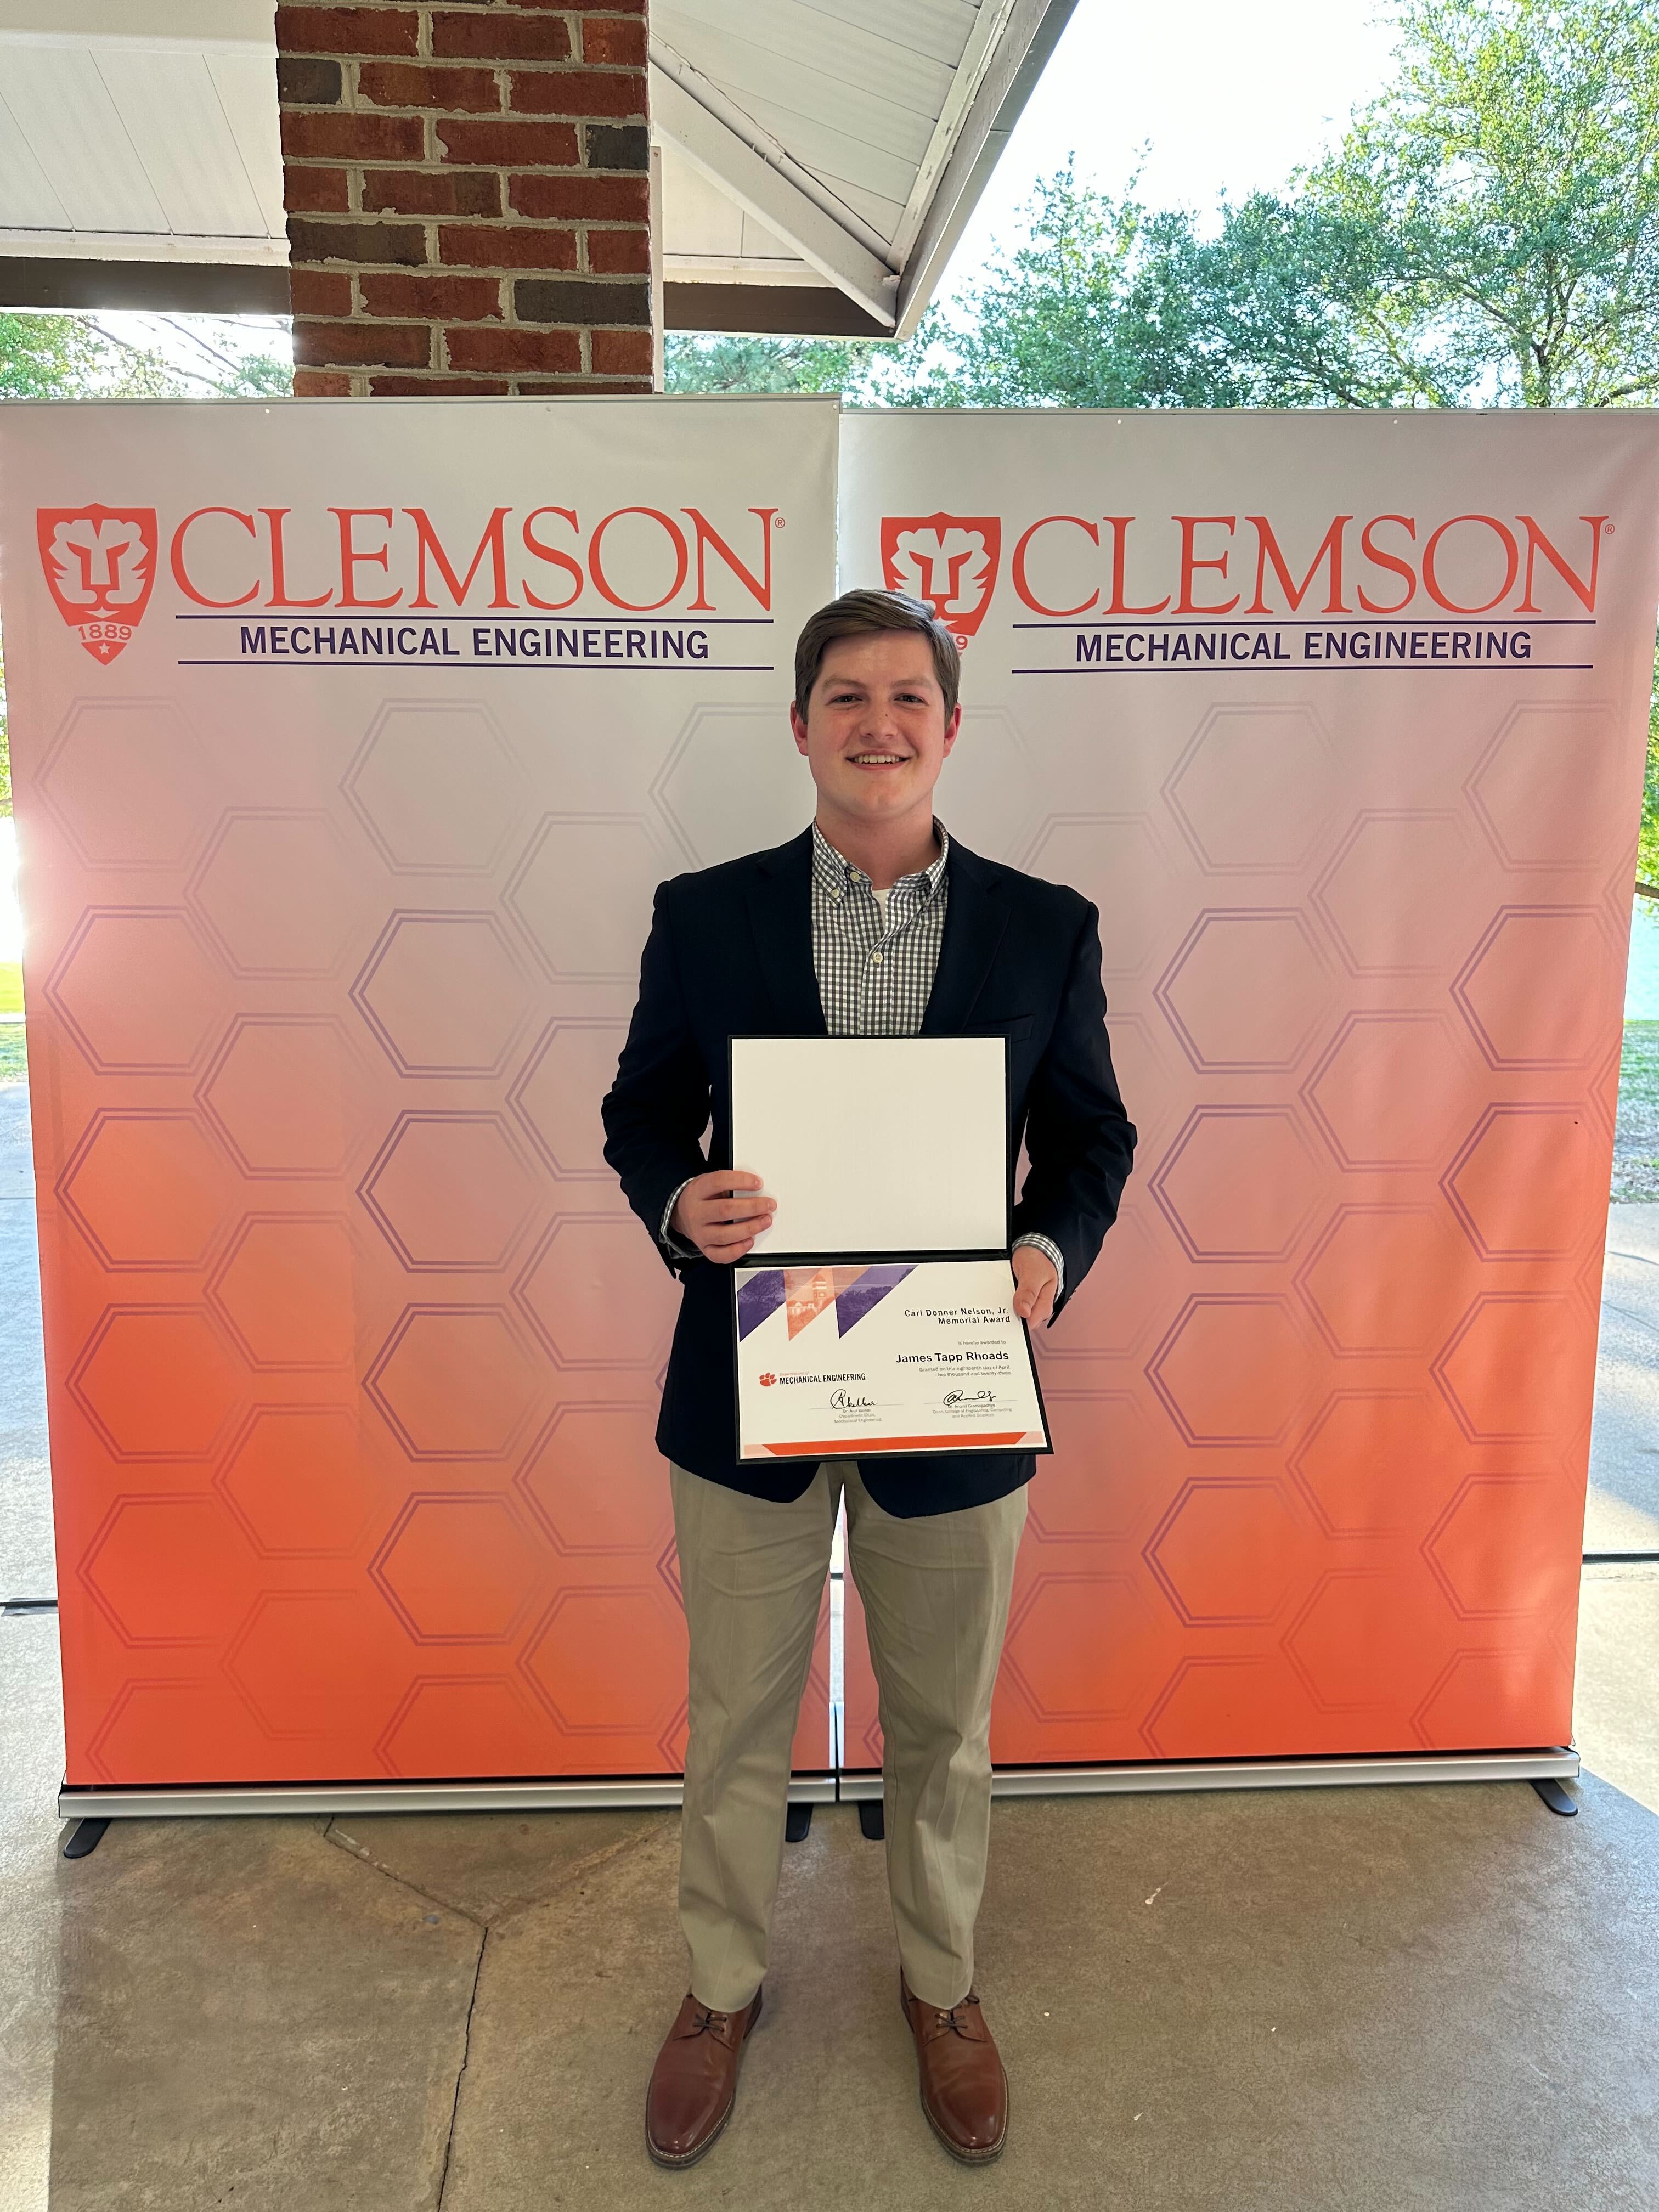
Tapp Rhoads received the Carl Donner Nelson, Jr. Memorial Award. Dr. Lv was also recognized as a Faculty Scholar in Clemson University’s School of Health Research.
Our paper, “Task-Invariant Centroidal Momentum Shaping for Lower-Limb Exoskeletons,” was published at the 61st Conference on Decision and Control.
Dr. Lv received the South Carolina Translational Research Improving Musculoskeletal Health (SC-TRIMH) targeted junior faculty award.
Dr. Lv joined Clemson University’s Department of Mechanical Engineering as an Assistant Professor.
Education and outreach
Our educational activities include faculty instruction, student design advising, and undergraduate research mentorship.
Dr. Lv has participated in Clemson’s Emerging Scholars and EUREKA! programs and serves as faculty advisor to the Clemson Baja Team. Undergraduate researchers also contribute to the laboratory through Creative Inquiry.
Outreach and educational activities →